 |
Galaxis Codebase
1.0.0
Team Galaxis software stack for the Carolo Cup 2023 - ROS2 based software
|
|
Galaxis Codebase
1.0.0
Team Galaxis software stack for the Carolo Cup 2023 - ROS2 based software
|
#include <SimulationAdapterNode.hpp>
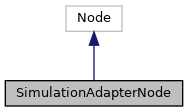
Public Member Functions | |
| SimulationAdapterNode () | |
| ~SimulationAdapterNode () | |
Private Member Functions | |
| void | simulationUpdateLoop () |
| void | updatePose () |
| void | vehicleControlCallback (SimulationVehicleControlType::SharedPtr msg) |
Private Attributes | |
| std::shared_ptr< CarPose > | m_carPose |
| std::atomic< float > | m_yawRate |
| std::atomic< float > | m_speedPerSecond |
| std::atomic< bool > | m_remoteControl |
| rclcpp::Publisher< gazebo_simulation::msg::SetModelPose >::SharedPtr | m_simulationCarRealStatePubSPtr |
| rclcpp::Subscription< ControlMotionType >::SharedPtr | m_controlValuesSubSPtr |
| rclcpp::Subscription< SimulationVehicleControlType >::SharedPtr | m_vehicleControlSubSPtr |
| std::mutex | m_carPoseMtx |
Definition at line 28 of file SimulationAdapterNode.hpp.
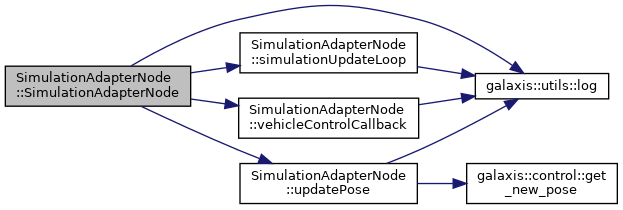
| SimulationAdapterNode::SimulationAdapterNode | ( | ) |
Definition at line 13 of file SimulationAdapterNode.cpp.
References galaxis::utils::log(), m_carPose, m_remoteControl, m_simulationCarRealStatePubSPtr, m_speedPerSecond, m_vehicleControlSubSPtr, m_yawRate, simulationUpdateLoop(), updatePose(), and vehicleControlCallback().
| SimulationAdapterNode::~SimulationAdapterNode | ( | ) |
Definition at line 45 of file SimulationAdapterNode.cpp.
|
private |
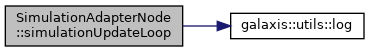
Definition at line 49 of file SimulationAdapterNode.cpp.
References galaxis::utils::log(), m_carPose, m_carPoseMtx, and m_simulationCarRealStatePubSPtr.
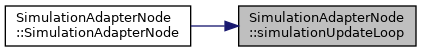
Referenced by SimulationAdapterNode().
|
private |
Definition at line 125 of file SimulationAdapterNode.cpp.
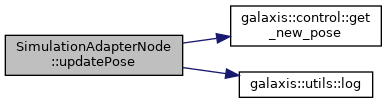
References galaxis::controllerSettings::carWheelbaseSimulationDrDrift, galaxis::control::get_new_pose(), galaxis::utils::log(), m_carPose, m_carPoseMtx, m_speedPerSecond, and m_yawRate.
Referenced by SimulationAdapterNode().
|
private |
Definition at line 92 of file SimulationAdapterNode.cpp.
References galaxis::utils::log(), m_carPose, m_carPoseMtx, m_remoteControl, m_speedPerSecond, and m_yawRate.
Referenced by SimulationAdapterNode().
|
private |
Definition at line 30 of file SimulationAdapterNode.hpp.
Referenced by SimulationAdapterNode(), simulationUpdateLoop(), updatePose(), and vehicleControlCallback().
|
private |
Definition at line 50 of file SimulationAdapterNode.hpp.
Referenced by simulationUpdateLoop(), updatePose(), and vehicleControlCallback().
|
private |
Definition at line 39 of file SimulationAdapterNode.hpp.
|
private |
Definition at line 33 of file SimulationAdapterNode.hpp.
Referenced by SimulationAdapterNode(), and vehicleControlCallback().
|
private |
Definition at line 36 of file SimulationAdapterNode.hpp.
Referenced by SimulationAdapterNode(), and simulationUpdateLoop().
|
private |
Definition at line 32 of file SimulationAdapterNode.hpp.
Referenced by SimulationAdapterNode(), updatePose(), and vehicleControlCallback().
|
private |
Definition at line 40 of file SimulationAdapterNode.hpp.
Referenced by SimulationAdapterNode().
|
private |
Definition at line 31 of file SimulationAdapterNode.hpp.
Referenced by SimulationAdapterNode(), updatePose(), and vehicleControlCallback().
 1.8.17