 |
Galaxis Codebase
1.0.0
Team Galaxis software stack for the Carolo Cup 2023 - ROS2 based software
|
|
Galaxis Codebase
1.0.0
Team Galaxis software stack for the Carolo Cup 2023 - ROS2 based software
|
Classes | |
| class | CarPose |
| class | TwoAndAHalfCarrots |
Typedefs | |
| typedef std::vector< std::shared_ptr< CarPose > > | CarPoseSeries |
Functions | |
| std::shared_ptr< CarPose > | get_new_pose (std::shared_ptr< CarPose > const p_currentPoseSPtr, float p_carWheelbase, float p_distance, float p_yawDiff) |
| std::ostream & | operator<< (std::ostream &strm, CarPose const &pose) |
| typedef std::vector<std::shared_ptr<CarPose> > galaxis::control::CarPoseSeries |
| std::shared_ptr< CarPose > galaxis::control::get_new_pose | ( | std::shared_ptr< CarPose > const | p_currentPoseSPtr, |
| float | p_carWheelbase, | ||
| float | p_distance, | ||
| float | p_yawDiff | ||
| ) |
Definition at line 168 of file control.cpp.
References MATH_PI.
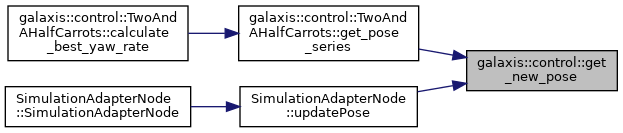
Referenced by galaxis::control::TwoAndAHalfCarrots::get_pose_series(), and SimulationAdapterNode::updatePose().
| std::ostream& galaxis::control::operator<< | ( | std::ostream & | strm, |
| CarPose const & | pose | ||
| ) |
Definition at line 13 of file pose.cpp.
References galaxis::control::CarPose::orientation, and galaxis::control::CarPose::position.
 1.8.17