 |
Galaxis Codebase
1.0.0
Team Galaxis software stack for the Carolo Cup 2023 - ROS2 based software
|
|
Galaxis Codebase
1.0.0
Team Galaxis software stack for the Carolo Cup 2023 - ROS2 based software
|
#include "utils/logger.hpp"#include "utils/poly.hpp"#include "utils/clock.hpp"#include "pose.hpp"#include <exception>#include <memory>#include <math.h>#include <vector>#include <Eigen/Dense>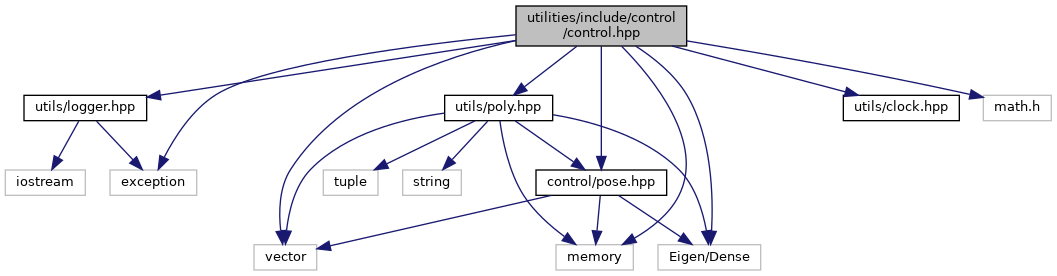
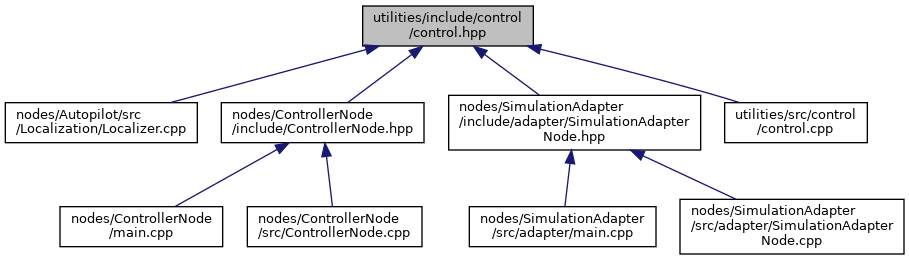
Go to the source code of this file.
Classes | |
| class | galaxis::control::TwoAndAHalfCarrots |
Namespaces | |
| galaxis | |
| galaxis::control | |
Functions | |
| std::shared_ptr< CarPose > | galaxis::control::get_new_pose (std::shared_ptr< CarPose > const p_currentPoseSPtr, float p_carWheelbase, float p_distance, float p_yawDiff) |
Variables | |
| constexpr float | MATH_PI = 3.141592653f |
| constexpr double | MATH_PI_DOUBLE = 3.141592653589793238 |
|
constexpr |
Definition at line 16 of file control.hpp.
Referenced by galaxis::control::get_new_pose().
|
constexpr |
Definition at line 17 of file control.hpp.
 1.8.17