 |
Galaxis Codebase
1.0.0
Team Galaxis software stack for the Carolo Cup 2023 - ROS2 based software
|
|
Galaxis Codebase
1.0.0
Team Galaxis software stack for the Carolo Cup 2023 - ROS2 based software
|
Classes | |
| class | MicroStopwatch |
Functions | |
| long long | get_time_now_ms () |
| long long | get_time_now_us () |
| shared_ptr< vector< string > > | read_from_file_to_string (string const &p_filepath) |
| shared_ptr< vector< float > > | read_from_file_to_float (string const &p_filepath) |
| template<typename T > | |
| void | write_to_file (string const &p_filepath, std::vector< std::vector< T >> const &p_data, string const &p_delimiter=",") |
| shared_ptr< std::map< std::string, std::string > > | read_configuration (string const &p_filepath) |
| template<typename... Args> | |
| void | log_nonewline (const Args &... args) |
| template<typename... Args> | |
| void | log_cout (const Args &... args) |
| template<typename... Args> | |
| void | log (const Args &... args) |
| template<typename... Args> | |
| void | log_warning (const Args &... args) |
| template<typename... Args> | |
| void | log_error (const Args &... args) |
| template<typename... Args> | |
| void | log_debug (const Args &... args) |
| float | evaluate_polynom (polynom const &p_polynomRef, float p_x) |
| double | evaluate_polynom (std::vector< double > const &p_polynomRef, double p_x) |
| float | calculate_gradient (std::vector< float > const &p_polynomRef, float p_x) |
| double | calculate_gradient (std::vector< double > const &p_polynomRef, double p_x) |
| double | calculate_gradient (DynamicPolynom p_polynomVecSPtr, double p_x) |
| shared_ptr< json > | read_json_file (std::string path) |
| shared_ptr< json > | read_system_settings (std::string key) |
| shared_ptr< std::string > | read_file_to_string (std::string path) |
| template<typename T , typename = typename std::enable_if<std::is_arithmetic<T>::value, T>::type> | |
| bool | check_parameter (rclcpp::Parameter const ¶m, rcl_interfaces::msg::SetParametersResult &result, T min=numeric_limits< T >::min(), T max=numeric_limits< T >::max()) |
| double galaxis::utils::calculate_gradient | ( | DynamicPolynom | p_polynomVecSPtr, |
| double | p_x | ||
| ) |
| double galaxis::utils::calculate_gradient | ( | std::vector< double > const & | p_polynomRef, |
| double | p_x | ||
| ) |
| float galaxis::utils::calculate_gradient | ( | std::vector< float > const & | p_polynomRef, |
| float | p_x | ||
| ) |
Definition at line 60 of file poly.cpp.
Referenced by AutoPilot::get_drive_information(), and main().

| bool galaxis::utils::check_parameter | ( | rclcpp::Parameter const & | param, |
| rcl_interfaces::msg::SetParametersResult & | result, | ||
| T | min = numeric_limits<T>::min(), |
||
| T | max = numeric_limits<T>::max() |
||
| ) |
Definition at line 29 of file settings.hpp.
| float galaxis::utils::evaluate_polynom | ( | polynom const & | p_polynomRef, |
| float | p_x | ||
| ) |
Definition at line 50 of file poly.cpp.
Referenced by galaxis::PolySpline::evaluate(), and AutoPilot::get_lane_centers_via_polynom_thread_helper().

| double galaxis::utils::evaluate_polynom | ( | std::vector< double > const & | p_polynomRef, |
| double | p_x | ||
| ) |
| long long galaxis::utils::get_time_now_ms | ( | ) |
| long long galaxis::utils::get_time_now_us | ( | ) |
Definition at line 13 of file clock.cpp.
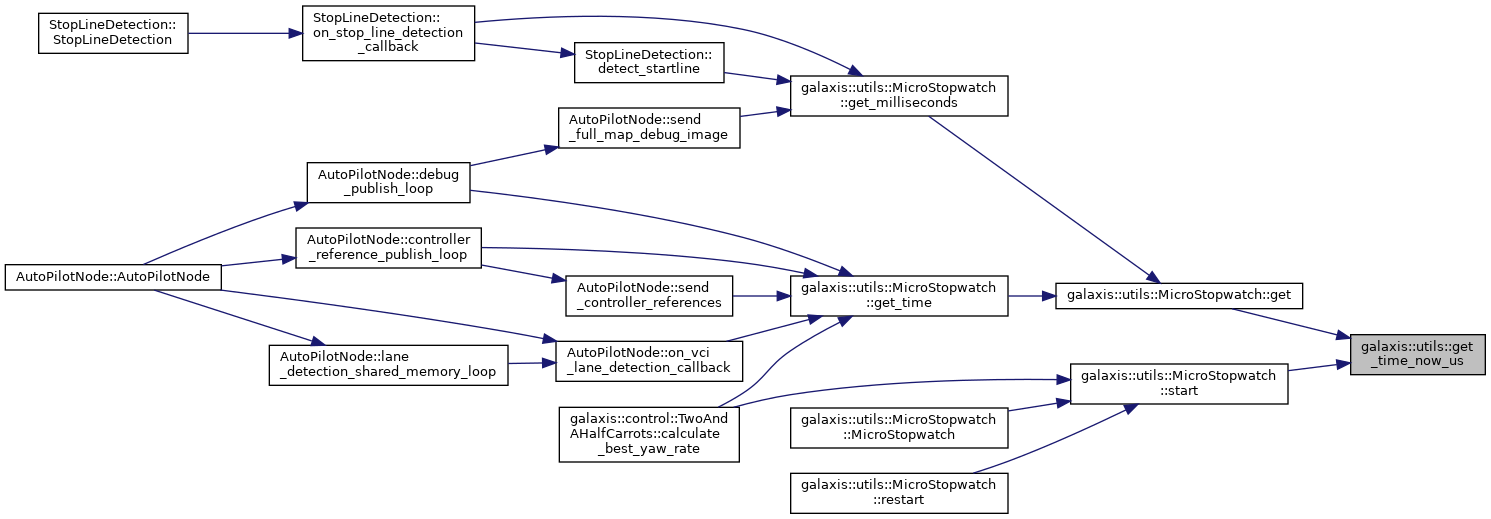
Referenced by galaxis::utils::MicroStopwatch::get(), and galaxis::utils::MicroStopwatch::start().
| void galaxis::utils::log | ( | const Args &... | args | ) |
Definition at line 33 of file logger.hpp.
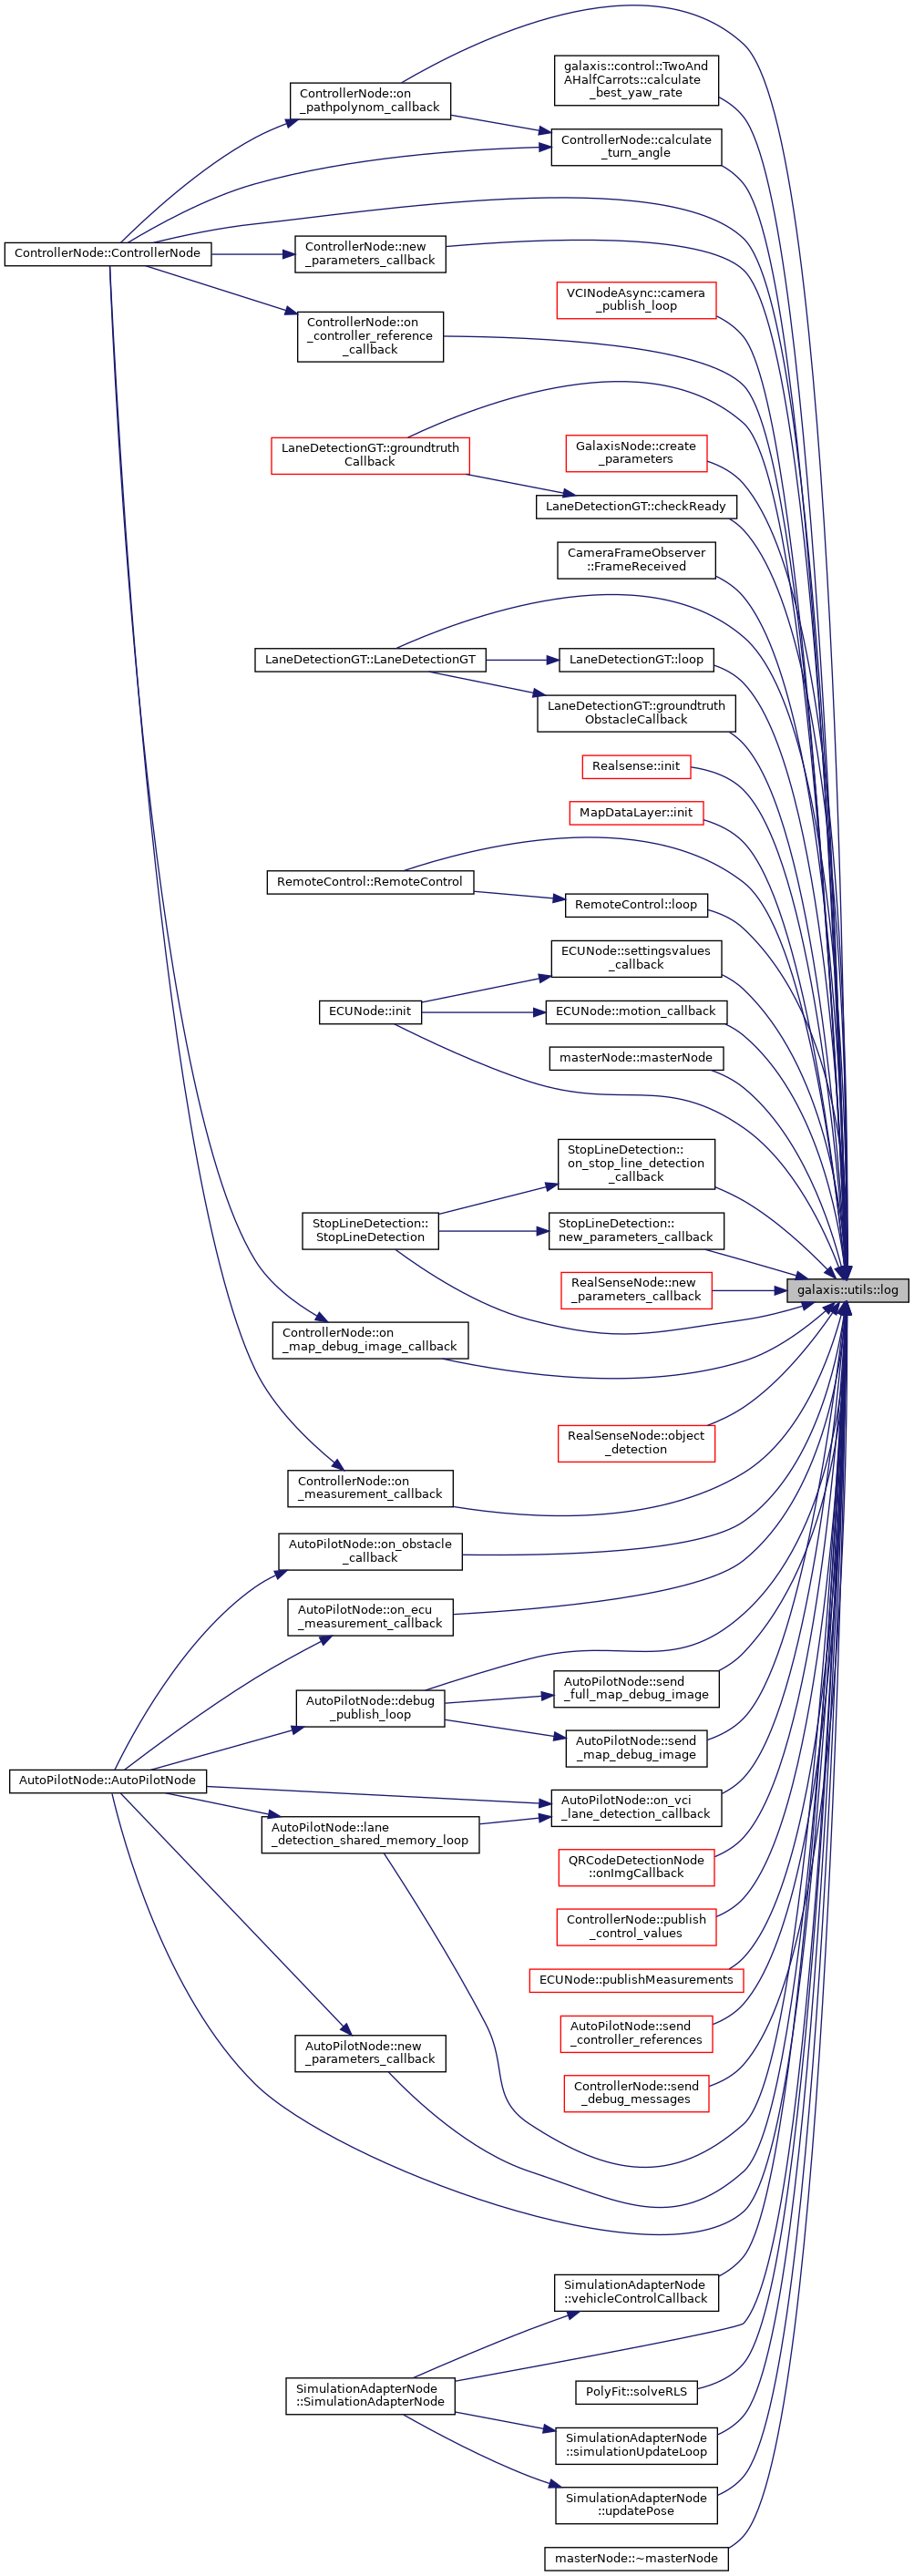
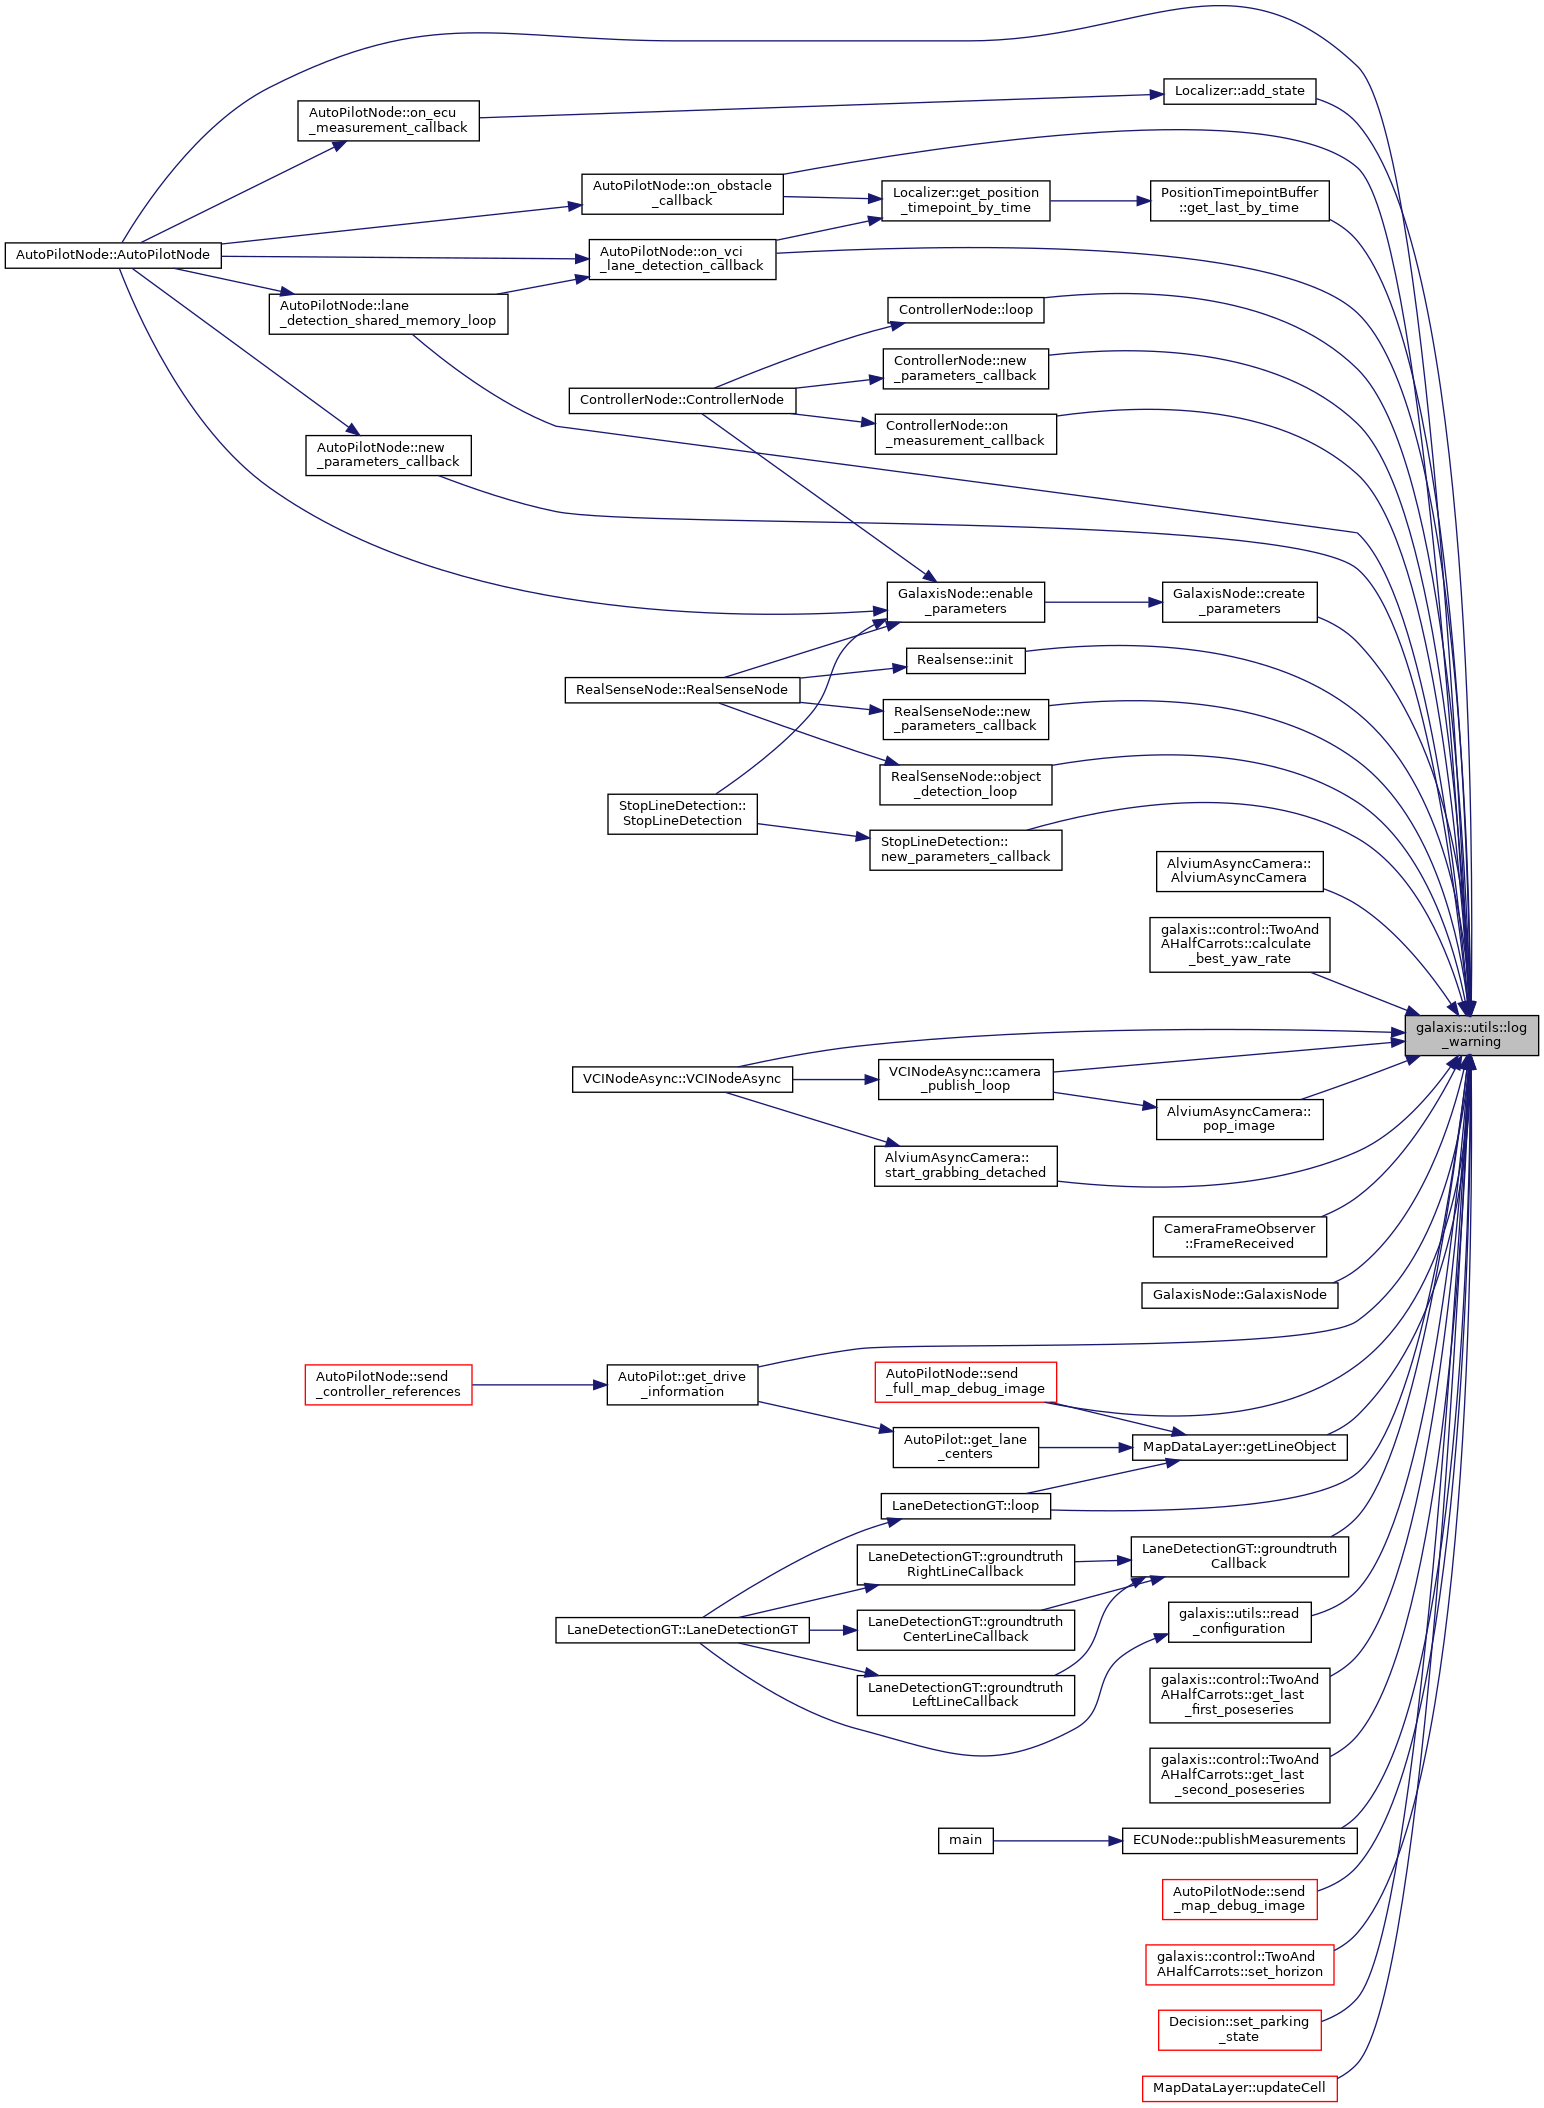
Referenced by AutoPilotNode::AutoPilotNode(), galaxis::control::TwoAndAHalfCarrots::calculate_best_yaw_rate(), ControllerNode::calculate_turn_angle(), VCINodeAsync::camera_publish_loop(), LaneDetectionGT::checkReady(), ControllerNode::ControllerNode(), GalaxisNode::create_parameters(), AutoPilotNode::debug_publish_loop(), CameraFrameObserver::FrameReceived(), LaneDetectionGT::groundtruthCallback(), LaneDetectionGT::groundtruthObstacleCallback(), ECUNode::init(), Realsense::init(), MapDataLayer::init(), AutoPilotNode::lane_detection_shared_memory_loop(), LaneDetectionGT::LaneDetectionGT(), RemoteControl::loop(), LaneDetectionGT::loop(), masterNode::masterNode(), ECUNode::motion_callback(), StopLineDetection::new_parameters_callback(), RealSenseNode::new_parameters_callback(), ControllerNode::new_parameters_callback(), AutoPilotNode::new_parameters_callback(), RealSenseNode::object_detection(), ControllerNode::on_controller_reference_callback(), AutoPilotNode::on_ecu_measurement_callback(), ControllerNode::on_map_debug_image_callback(), ControllerNode::on_measurement_callback(), AutoPilotNode::on_obstacle_callback(), ControllerNode::on_pathpolynom_callback(), StopLineDetection::on_stop_line_detection_callback(), AutoPilotNode::on_vci_lane_detection_callback(), QRCodeDetectionNode::onImgCallback(), ControllerNode::publish_control_values(), ECUNode::publishMeasurements(), RemoteControl::RemoteControl(), AutoPilotNode::send_controller_references(), ControllerNode::send_debug_messages(), AutoPilotNode::send_full_map_debug_image(), AutoPilotNode::send_map_debug_image(), ECUNode::settingsvalues_callback(), SimulationAdapterNode::SimulationAdapterNode(), SimulationAdapterNode::simulationUpdateLoop(), PolyFit< T >::solveRLS(), StopLineDetection::StopLineDetection(), SimulationAdapterNode::updatePose(), SimulationAdapterNode::vehicleControlCallback(), and masterNode::~masterNode().
| void galaxis::utils::log_cout | ( | const Args &... | args | ) |
Definition at line 25 of file logger.hpp.
Referenced by Decision::update().

| void galaxis::utils::log_debug | ( | const Args &... | args | ) |
Definition at line 62 of file logger.hpp.
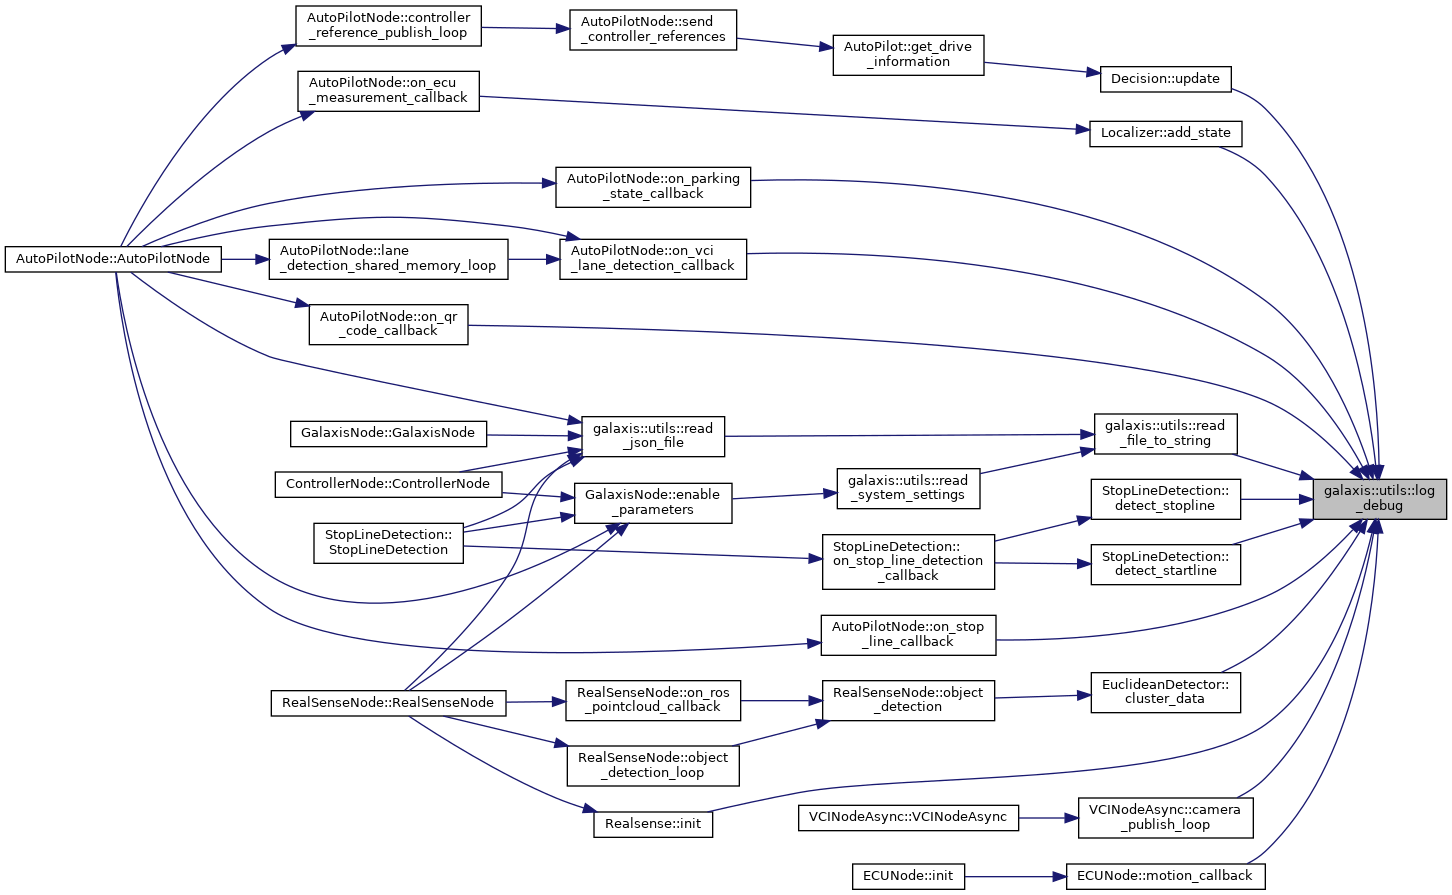
Referenced by Localizer::add_state(), VCINodeAsync::camera_publish_loop(), EuclideanDetector::cluster_data(), StopLineDetection::detect_startline(), StopLineDetection::detect_stopline(), Realsense::init(), ECUNode::motion_callback(), AutoPilotNode::on_parking_state_callback(), AutoPilotNode::on_qr_code_callback(), AutoPilotNode::on_stop_line_callback(), AutoPilotNode::on_vci_lane_detection_callback(), read_file_to_string(), and Decision::update().
| void galaxis::utils::log_error | ( | const Args &... | args | ) |
Definition at line 50 of file logger.hpp.
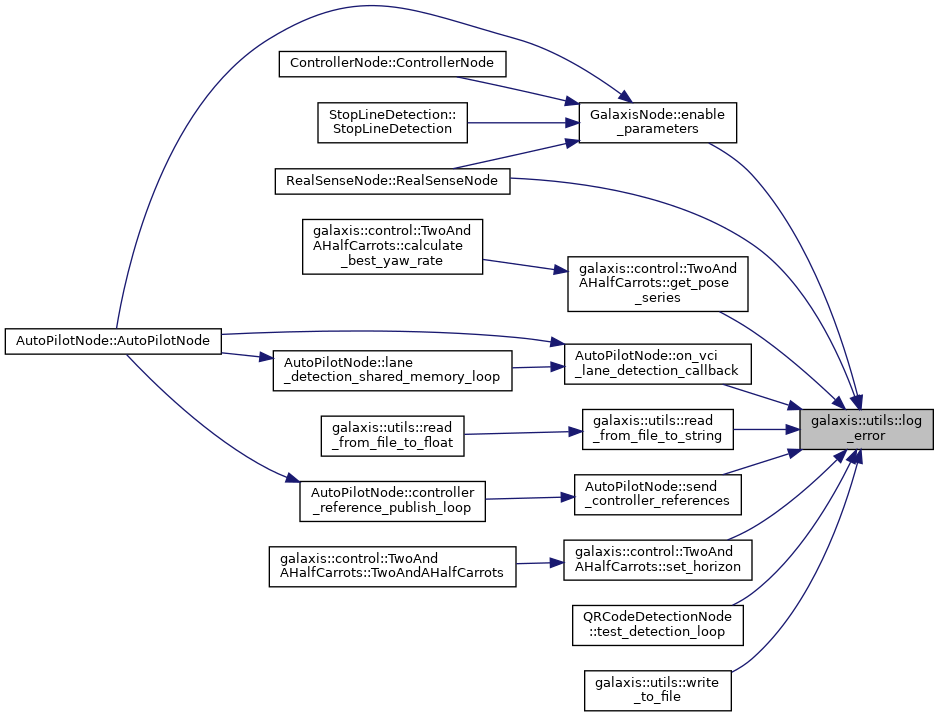
Referenced by GalaxisNode::enable_parameters(), galaxis::control::TwoAndAHalfCarrots::get_pose_series(), AutoPilotNode::on_vci_lane_detection_callback(), read_from_file_to_string(), RealSenseNode::RealSenseNode(), AutoPilotNode::send_controller_references(), galaxis::control::TwoAndAHalfCarrots::set_horizon(), QRCodeDetectionNode::test_detection_loop(), and write_to_file().
| void galaxis::utils::log_nonewline | ( | const Args &... | args | ) |
Definition at line 18 of file logger.hpp.
Referenced by RemoteControl::loop().

| void galaxis::utils::log_warning | ( | const Args &... | args | ) |
Definition at line 41 of file logger.hpp.
Referenced by Localizer::add_state(), AlviumAsyncCamera::AlviumAsyncCamera(), AutoPilotNode::AutoPilotNode(), galaxis::control::TwoAndAHalfCarrots::calculate_best_yaw_rate(), VCINodeAsync::camera_publish_loop(), GalaxisNode::create_parameters(), CameraFrameObserver::FrameReceived(), GalaxisNode::GalaxisNode(), AutoPilot::get_drive_information(), PositionTimepointBuffer::get_last_by_time(), galaxis::control::TwoAndAHalfCarrots::get_last_first_poseseries(), galaxis::control::TwoAndAHalfCarrots::get_last_second_poseseries(), MapDataLayer::getLineObject(), LaneDetectionGT::groundtruthCallback(), Realsense::init(), AutoPilotNode::lane_detection_shared_memory_loop(), ControllerNode::loop(), LaneDetectionGT::loop(), StopLineDetection::new_parameters_callback(), RealSenseNode::new_parameters_callback(), ControllerNode::new_parameters_callback(), AutoPilotNode::new_parameters_callback(), RealSenseNode::object_detection_loop(), ControllerNode::on_measurement_callback(), AutoPilotNode::on_obstacle_callback(), AutoPilotNode::on_vci_lane_detection_callback(), AlviumAsyncCamera::pop_image(), ECUNode::publishMeasurements(), read_configuration(), AutoPilotNode::send_full_map_debug_image(), AutoPilotNode::send_map_debug_image(), galaxis::control::TwoAndAHalfCarrots::set_horizon(), Decision::set_parking_state(), AlviumAsyncCamera::start_grabbing_detached(), MapDataLayer::updateCell(), and VCINodeAsync::VCINodeAsync().
| shared_ptr< std::map< std::string, std::string > > galaxis::utils::read_configuration | ( | string const & | p_filepath | ) |
Definition at line 41 of file file.cpp.
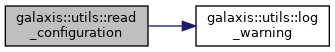
References log_warning().
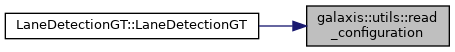
Referenced by LaneDetectionGT::LaneDetectionGT().
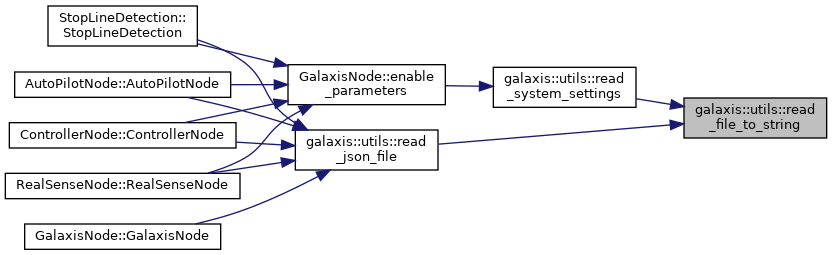
| shared_ptr< std::string > galaxis::utils::read_file_to_string | ( | std::string | path | ) |
Definition at line 24 of file settings.cpp.
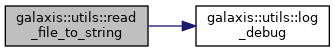
References log_debug().
Referenced by read_json_file(), and read_system_settings().
| shared_ptr< vector< float > > galaxis::utils::read_from_file_to_float | ( | string const & | p_filepath | ) |
Definition at line 29 of file file.cpp.
References read_from_file_to_string().

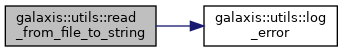
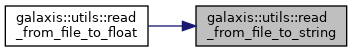
| shared_ptr< vector< string > > galaxis::utils::read_from_file_to_string | ( | string const & | p_filepath | ) |
Definition at line 5 of file file.cpp.
References log_error().
Referenced by read_from_file_to_float().
| shared_ptr< json > galaxis::utils::read_json_file | ( | std::string | path | ) |
Definition at line 5 of file settings.cpp.
References read_file_to_string().
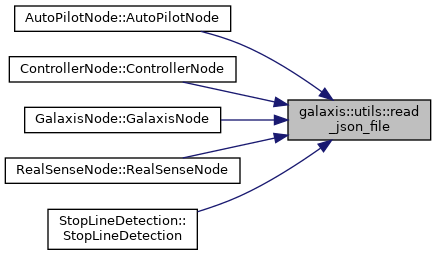
Referenced by AutoPilotNode::AutoPilotNode(), ControllerNode::ControllerNode(), GalaxisNode::GalaxisNode(), RealSenseNode::RealSenseNode(), and StopLineDetection::StopLineDetection().
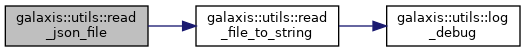
| shared_ptr< json > galaxis::utils::read_system_settings | ( | std::string | key | ) |
Definition at line 14 of file settings.cpp.
References read_file_to_string().
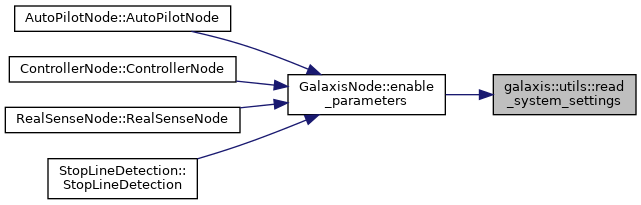
Referenced by GalaxisNode::enable_parameters().
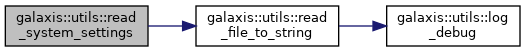
| void galaxis::utils::write_to_file | ( | string const & | p_filepath, |
| std::vector< std::vector< T >> const & | p_data, | ||
| string const & | p_delimiter = "," |
||
| ) |
Definition at line 21 of file file.hpp.
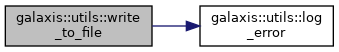
References log_error().
 1.8.17