 |
Galaxis Codebase
1.0.0
Team Galaxis software stack for the Carolo Cup 2023 - ROS2 based software
|
|
Galaxis Codebase
1.0.0
Team Galaxis software stack for the Carolo Cup 2023 - ROS2 based software
|
#include <map>#include <unordered_map>#include <array>#include <memory>#include <mutex>#include <atomic>#include <galaxis/linatypes.hpp>#include <galaxis/messages.hpp>#include <galaxis/AutopilotSettings.hpp>#include <sensor_msgs/msg/image.hpp>#include "MapClasses.hpp"#include <boost/asio.hpp>#include <boost/asio/thread_pool.hpp>#include <shared_mutex>#include <rclcpp/rclcpp.hpp>
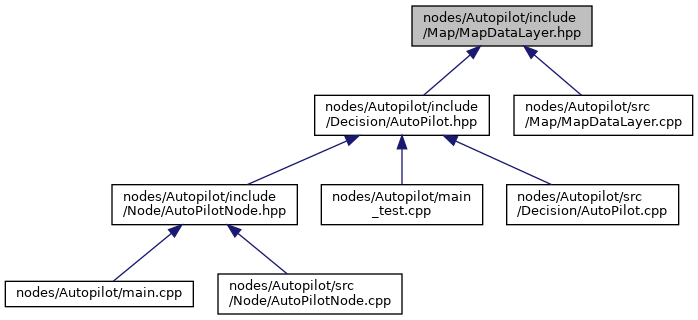
Go to the source code of this file.
Classes | |
| struct | MapCell |
| class | MapDataLayer |
Variables | |
| constexpr uint8_t | MAPCELL_MAXVALUE = 255 |
| constexpr int | MAP_SIZE = 20000 |
|
constexpr |
Definition at line 53 of file MapDataLayer.hpp.
Referenced by MapDataLayer::init().
|
constexpr |
Definition at line 43 of file MapDataLayer.hpp.
 1.8.17