 |
Galaxis Codebase
1.0.0
Team Galaxis software stack for the Carolo Cup 2023 - ROS2 based software
|
|
Galaxis Codebase
1.0.0
Team Galaxis software stack for the Carolo Cup 2023 - ROS2 based software
|
Functions | |
| float | erpmToVelocity (float const p_erpm) |
| returns the velocity in [m/s] for a given ERPM More... | |
| float | velocityToErpm (float const p_velocity) |
Variables | |
| constexpr float | minimumCurrent = -10.f |
| constexpr float | maximumCurrent = 10.f |
| constexpr float | maximumSpeed = 2.5 |
| constexpr float | maximumBrakeCurrent = 6.0 |
| float galaxis::motorSettings::erpmToVelocity | ( | float const | p_erpm | ) |
returns the velocity in [m/s] for a given ERPM
| erpm | the ERPM to convert |
Definition at line 5 of file motorSettings.cpp.
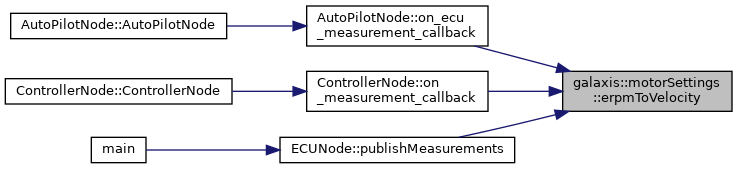
Referenced by AutoPilotNode::on_ecu_measurement_callback(), ControllerNode::on_measurement_callback(), and ECUNode::publishMeasurements().
| float galaxis::motorSettings::velocityToErpm | ( | float const | p_velocity | ) |
Definition at line 9 of file motorSettings.cpp.
Referenced by ControllerNode::loop().

|
constexpr |
Definition at line 11 of file motorSettings.hpp.
|
constexpr |
Definition at line 9 of file motorSettings.hpp.
|
constexpr |
Definition at line 10 of file motorSettings.hpp.
|
constexpr |
Definition at line 8 of file motorSettings.hpp.
 1.8.17