 |
Galaxis Codebase
1.0.0
Team Galaxis software stack for the Carolo Cup 2023 - ROS2 based software
|
|
Galaxis Codebase
1.0.0
Team Galaxis software stack for the Carolo Cup 2023 - ROS2 based software
|
#include "masterNode.hpp"#include <rclcpp/rclcpp.hpp>#include <galaxis/node_ros_pubsub_wrapper.hpp>#include <functional>#include <string>#include <sstream>#include <galaxis/cuprules.hpp>#include <utils/logger.hpp>#include <unistd.h>
Go to the source code of this file.
Functions | |
| static long long | __get_time_now_ms () |
|
static |
Definition at line 13 of file masterNode.cpp.
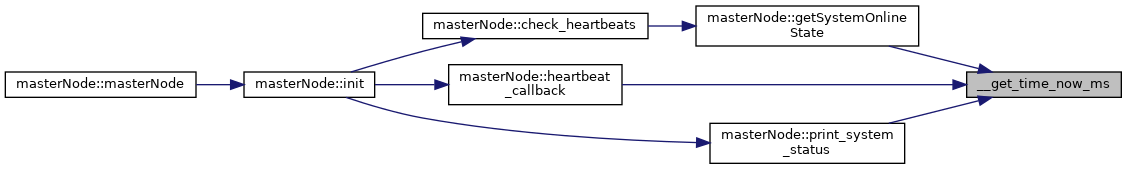
Referenced by masterNode::getSystemOnlineState(), masterNode::heartbeat_callback(), and masterNode::print_system_status().
 1.8.17