 |
Galaxis Codebase
1.0.0
Team Galaxis software stack for the Carolo Cup 2023 - ROS2 based software
|
|
Galaxis Codebase
1.0.0
Team Galaxis software stack for the Carolo Cup 2023 - ROS2 based software
|
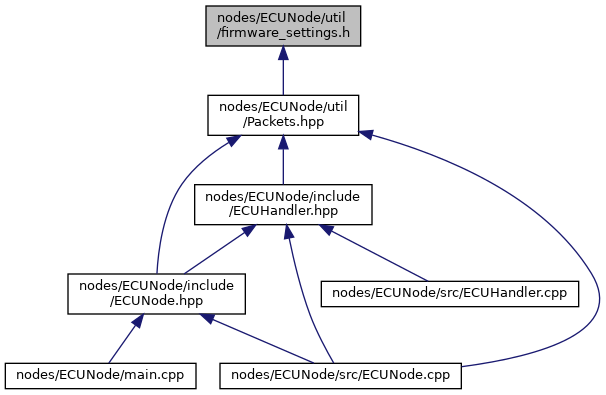
Go to the source code of this file.
Functions | |
| struct | __attribute__ ((packed, aligned(1))) |
| struct | __attribute__ ((packed)) |
Variables | |
| ServoOffset_t | |
| FirmwareSetup_t | |
| union { | |
| char wrong_offset_motor_current_max [(offsetof(FirmwareSetup_t, motor_current_max)==0) ? 1 :-1] | |
| char wrong_offset_erpm_max [(offsetof(FirmwareSetup_t, erpm_max)==4) ? 1 :-1] | |
| char wrong_offset_max_brake_current [(offsetof(FirmwareSetup_t, max_brake_current)==4+4) ? 1 :-1] | |
| char wrong_offset_max_servo_offset [(offsetof(FirmwareSetup_t, max_servo_offset)==12) ? 1 :-1] | |
| char wrong_offset_manual_override_difference [(offsetof(FirmwareSetup_t, manual_override_difference)==12+4) ? 1 :-1] | |
| char wrong_offset_use_rc_to_steer [(offsetof(FirmwareSetup_t, use_rc_to_steer)==12+4+2) ? 1 :-1] | |
| char wrong_offset_rc_use_erpm [(offsetof(FirmwareSetup_t, rc_use_erpm)==12+4+2+1) ? 1 :-1] | |
| char wrong_offset_servo_offset [(offsetof(FirmwareSetup_t, servo_offset)==12+4+2+1+1) ? 1 :-1] | |
| char wrong_offset_motor_current_max_rc [(offsetof(FirmwareSetup_t, motor_current_max_rc)==12+4+2+1+1+4) ? 1 :-1] | |
| char wrong_offset_erpm_max_rc [(offsetof(FirmwareSetup_t, erpm_max_rc)==12+4+2+1+1+4+4) ? 1 :-1] | |
| char wrong_sizeof_packet [(sizeof(FirmwareSetup_t)==32) ? 1 :-1] | |
| } | FirmwareSetupTest |
| struct __attribute__ | ( | (packed) | ) |
Speed value for the motor
This variable usually would be used for system identification
The motor current in Ampere
Servo values are between [-100,100]
Stores the states for car lights and scenario settings
There are 2 bits for the following states The order is the following: Bits: [13,12|11,10|9,8|7,6|5,4|3,2|1,0] [scenario3,scenario2,scenario1,brakes,blinkerRight,blinkerLeft,headlight]
Enable/Disable Brakes (1 for enable, 0 for disable, otherwise undefined)
Definition at line 9 of file firmware_settings.h.
References cuprules::modes::training::erpm_max_rc, cuprules::modes::training::rc_use_erpm, and ServoOffset_t.
| struct __attribute__ | ( | (packed, aligned(1)) | ) |
Definition at line 4 of file firmware_settings.h.
| FirmwareSetup_t |
Definition at line 33 of file firmware_settings.h.
Referenced by __attribute__().
| union { ... } FirmwareSetupTest |
| ServoOffset_t |
Definition at line 7 of file firmware_settings.h.
Referenced by __attribute__().
| char wrong_offset_erpm_max[(offsetof(FirmwareSetup_t, erpm_max)==4) ? 1 :-1] |
Definition at line 44 of file firmware_settings.h.
| char wrong_offset_erpm_max_rc[(offsetof(FirmwareSetup_t, erpm_max_rc)==12+4+2+1+1+4+4) ? 1 :-1] |
Definition at line 60 of file firmware_settings.h.
| char wrong_offset_manual_override_difference[(offsetof(FirmwareSetup_t, manual_override_difference)==12+4) ? 1 :-1] |
Definition at line 50 of file firmware_settings.h.
| char wrong_offset_max_brake_current[(offsetof(FirmwareSetup_t, max_brake_current)==4+4) ? 1 :-1] |
Definition at line 46 of file firmware_settings.h.
| char wrong_offset_max_servo_offset[(offsetof(FirmwareSetup_t, max_servo_offset)==12) ? 1 :-1] |
Definition at line 48 of file firmware_settings.h.
| char wrong_offset_motor_current_max[(offsetof(FirmwareSetup_t, motor_current_max)==0) ? 1 :-1] |
Definition at line 42 of file firmware_settings.h.
| char wrong_offset_motor_current_max_rc[(offsetof(FirmwareSetup_t, motor_current_max_rc)==12+4+2+1+1+4) ? 1 :-1] |
Definition at line 58 of file firmware_settings.h.
| char wrong_offset_rc_use_erpm[(offsetof(FirmwareSetup_t, rc_use_erpm)==12+4+2+1) ? 1 :-1] |
Definition at line 54 of file firmware_settings.h.
| char wrong_offset_servo_offset[(offsetof(FirmwareSetup_t, servo_offset)==12+4+2+1+1) ? 1 :-1] |
Definition at line 56 of file firmware_settings.h.
| char wrong_offset_use_rc_to_steer[(offsetof(FirmwareSetup_t, use_rc_to_steer)==12+4+2) ? 1 :-1] |
Definition at line 52 of file firmware_settings.h.
| char wrong_sizeof_packet[(sizeof(FirmwareSetup_t)==32) ? 1 :-1] |
Definition at line 62 of file firmware_settings.h.
 1.8.17