Galaxis Codebase  1.0.0
Team Galaxis software stack for the Carolo Cup 2023 - ROS2 based software
main.cpp File Reference
#include <functional>
#include "rclcpp/rclcpp.hpp"
#include "ECUNode.hpp"
#include "std_msgs/msg/string.hpp"
#include <galaxis/messages.hpp>
Include dependency graph for main.cpp:

Go to the source code of this file.

Functions

int main (int argc, char *argv[])
 

Function Documentation

◆ main()

int main ( int  argc,
char *  argv[] 
)

Definition at line 7 of file main.cpp.

7  {
8  rclcpp::init(argc, argv);
9 
10  auto node = std::make_shared<ECUNode>();
11  auto handler = std::make_shared<ECUHandler>();
12 
13  node->init(handler);
14  handler->init(
16  node.get(),
17  std::placeholders::_1,
18  std::placeholders::_2));
19 
20  rclcpp::spin(node);
21  rclcpp::shutdown();
22  return 0;
23 }

References ECUNode::publishMeasurements().
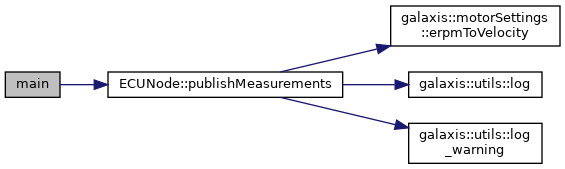
Here is the call graph for this function:
ECUNode::publishMeasurements
void publishMeasurements(const EcuPacket *const packet, const std::array< std::chrono::duration< double, std::milli >, 10 > &diff_ms)
Publishes the new Measurements from the ECU on the apropriate Publishers.
Definition: ECUNode.cpp:140

