 |
Galaxis Codebase
1.0.0
Team Galaxis software stack for the Carolo Cup 2023 - ROS2 based software
|
|
Galaxis Codebase
1.0.0
Team Galaxis software stack for the Carolo Cup 2023 - ROS2 based software
|
#include "lanedetection-groundtruth/LaneDetectionGT.hpp"#include <galaxis/node_ros_pubsub_wrapper.hpp>#include <iostream>#include <stdio.h>#include <utils/logger.hpp>#include <utils/file.hpp>#include <galaxis/AutopilotSettings.hpp>#include <unistd.h>#include <thread>#include "lanedetection-groundtruth/MapClasses.hpp"#include <sensor_msgs/image_encodings.hpp>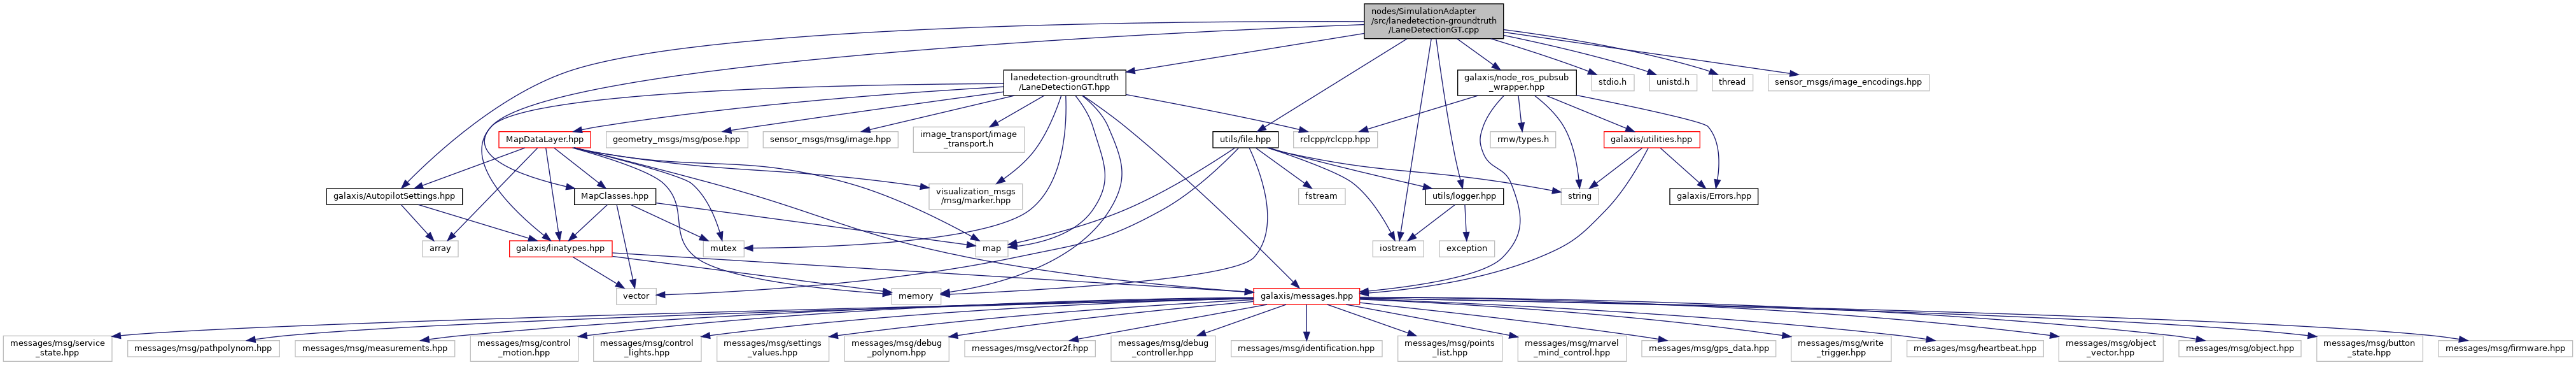
Go to the source code of this file.
Variables | |
| constexpr double | MATH_PI_DOUBLE = 3.141592653589793238 |
|
constexpr |
Definition at line 23 of file LaneDetectionGT.cpp.
Referenced by LaneDetectionGT::carPoseCallback().
 1.8.17